Skip to content

John D. Aduroja

Mechatronics Engineering · MTSU

I am a rising senior in Mechatronics Engineering at Middle Tennessee State University, and a research assistant in the Intelligent & Autonomous Systems Computing Lab, where I build autonomous robotic systems on ROS2 using reinforcement learning and agentic AI architectures — path planning, multi-agent coordination, and LiDAR/IMU/camera perception pipelines for disaster-response robotics.

My current research is a training-free, interpretable alternative to learning-based overtaking in multi-agent F1TENTH racing: Frenet-frame trajectory planning with traction-aware speed control. Earlier, I designed, built, and programmed autonomous Melty-Brain combat robots for the National Robotics Challenge and defended an Honors thesis on their embedded AI, control systems, and ethical and safety frameworks.

I am seeking doctoral study in autonomous robotic systems, at the intersection of reinforcement learning, agentic AI, and embedded control. Long-term aim: robots that perceive, reason, and adapt under uncertainty in unstructured, safety-critical environments.

📢 If you are interested in collaboration, please feel free to reach out via email.
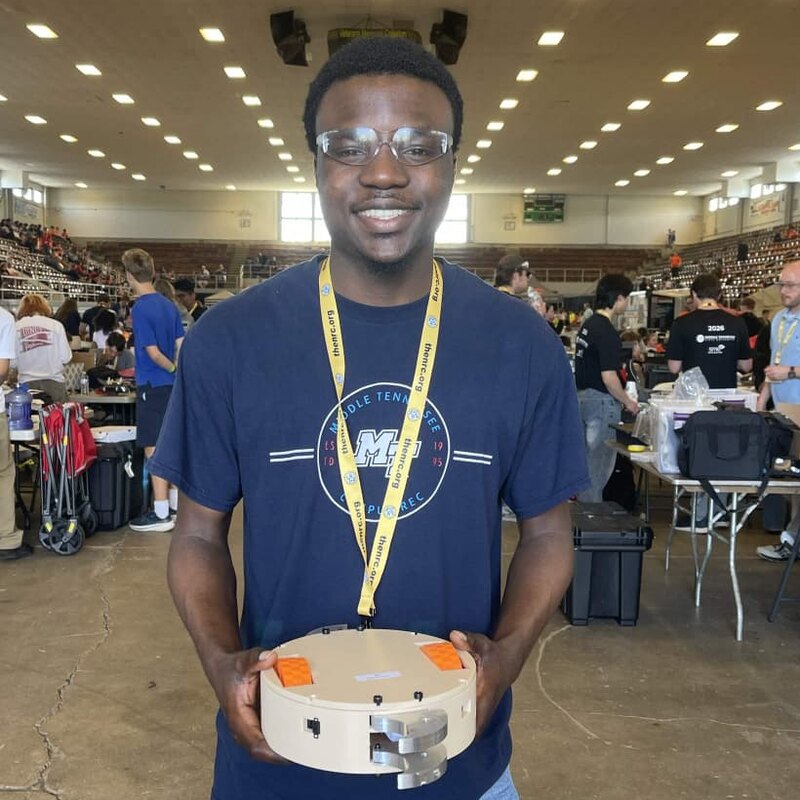
Portrait of John D. Aduroja, Mechatronics Engineering · MTSU

Murfreesboro, TN

Research Interests

  • Autonomous Robotics
  • Reinforcement Learning
  • Agentic AI & Multi-Agent Systems
  • Robot Safety & Ethics
  • Embedded Control
  • Motion Planning

News

  1. Started a team research project on geometry-based overtaking and traction-aware speed control for multi-agent F1TENTH racing.

  2. Paper "Self Evolving Agent for Autonomous Drone Navigation" submitted to Machine Learning (Springer).

  3. Joined the Intelligent & Autonomous Systems Computing Lab at MTSU as a Research Assistant, working on agentic AI and ROS2 for autonomous robots.

  4. Interned at Evva Robotics, designing and building a humanoid robot; coordinated the TDOT-sponsored National Summer Transportation Institute.

  5. Built a hybrid ROS2 racing stack on the F1TENTH platform, coupling Pure Pursuit raceline tracking with reactive Follow-the-Gap obstacle avoidance.

  6. Successfully defended the Honors thesis "The Machinations and Ethics of Autonomous and Non-Autonomous Melty-Brain Combat Robots."

Selected Publications

Springer MLSelectedSubmitted

Self Evolving Agent for Autonomous Drone Navigation

Authors: J. Aduroja, Y. Sarker, M. A. Hossain

Machine Learning (Springer),